A garden robot that never knew where it was
Seven tasks, two minutes, and no way to know its own position. It finished first out of 68 teams and 272 engineers, with a perfect score.
Built for a first-year honors engineering course at Ohio State, the robot had to rotate a compost drum, carry a bucket of apples up a ramp, press the right humidifier button, flip whichever fertilizer lever the course asked for, and open and close a greenhouse window — alone, on a two-minute clock.
The course would tell it what to do. It would not tell it where it was. Everything else follows from that.
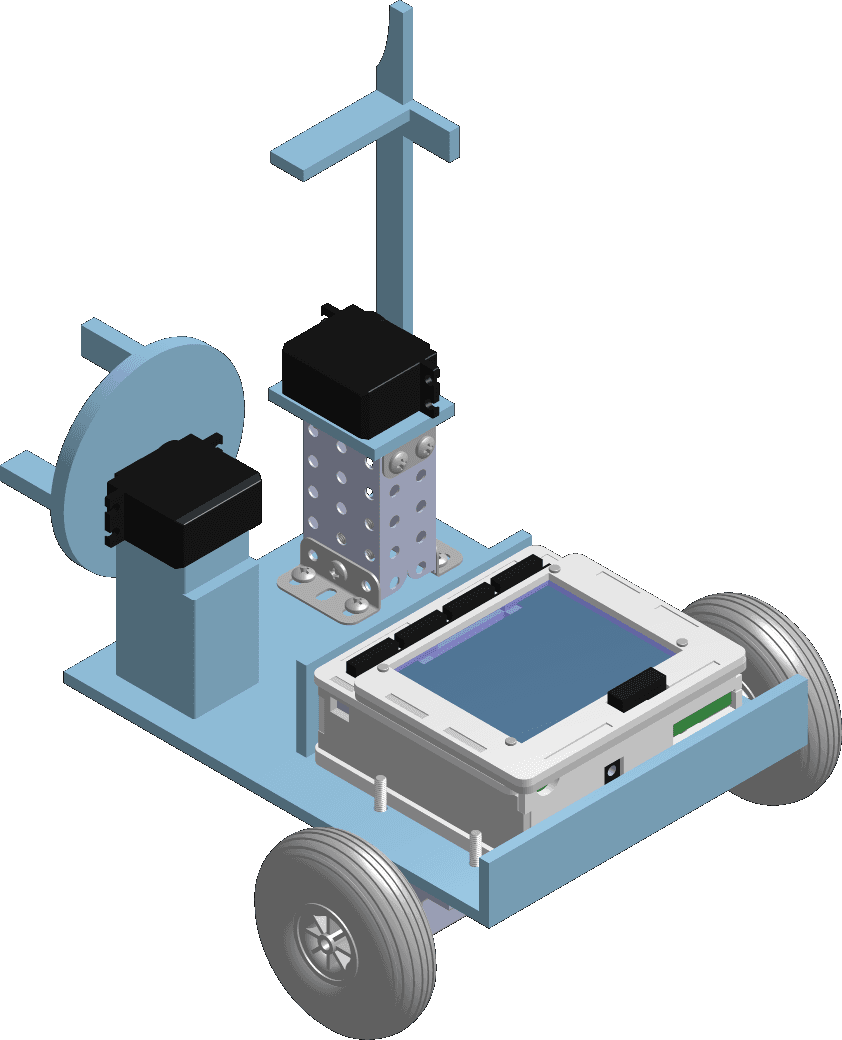
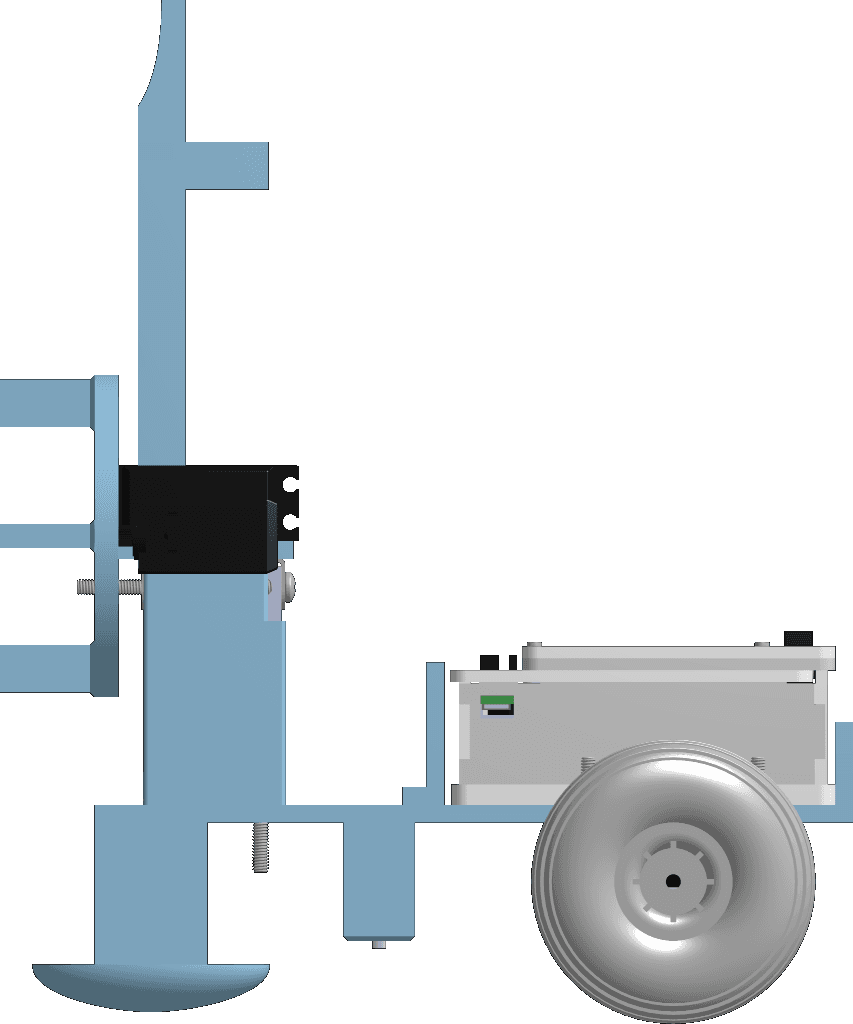
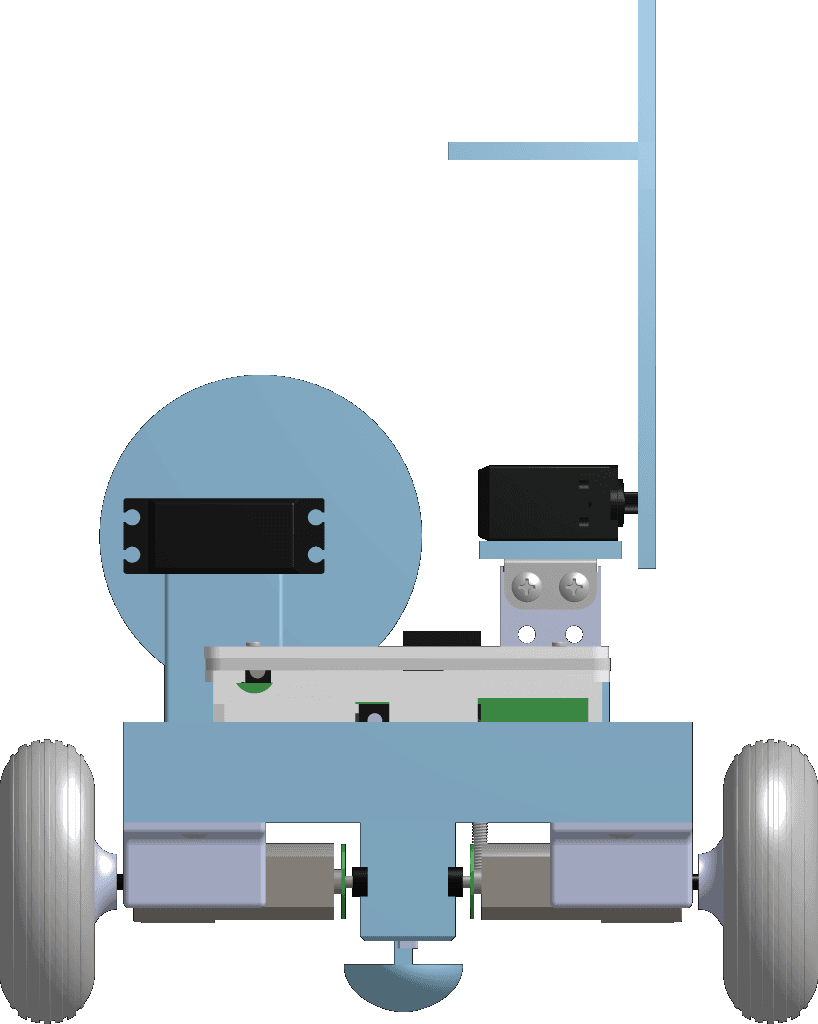
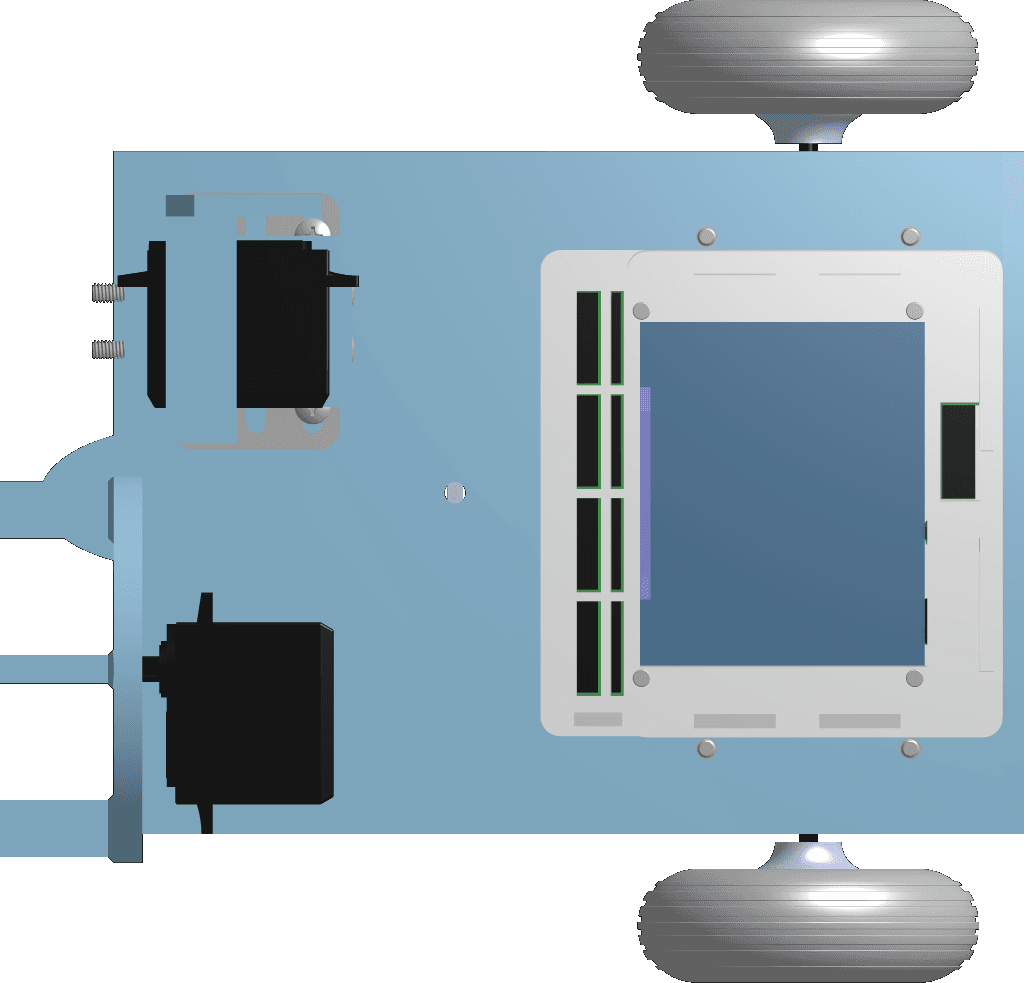
From the team’s CAD assembly drawing. 9″ wide, 10.7″ tall.
- Course
- ENGR 1282.01H · The Ohio State UniversityFundamentals of Engineering for Honors
- Term
- Spring 2025
- Team
- Group C9 — Ethan Mark, Connor Nock, Thomas Sobodosh, Ben Ni
- My role
- Programmer — wrote all of the autonomous logicAlso electrical wiring, a modified servo, the physical build.